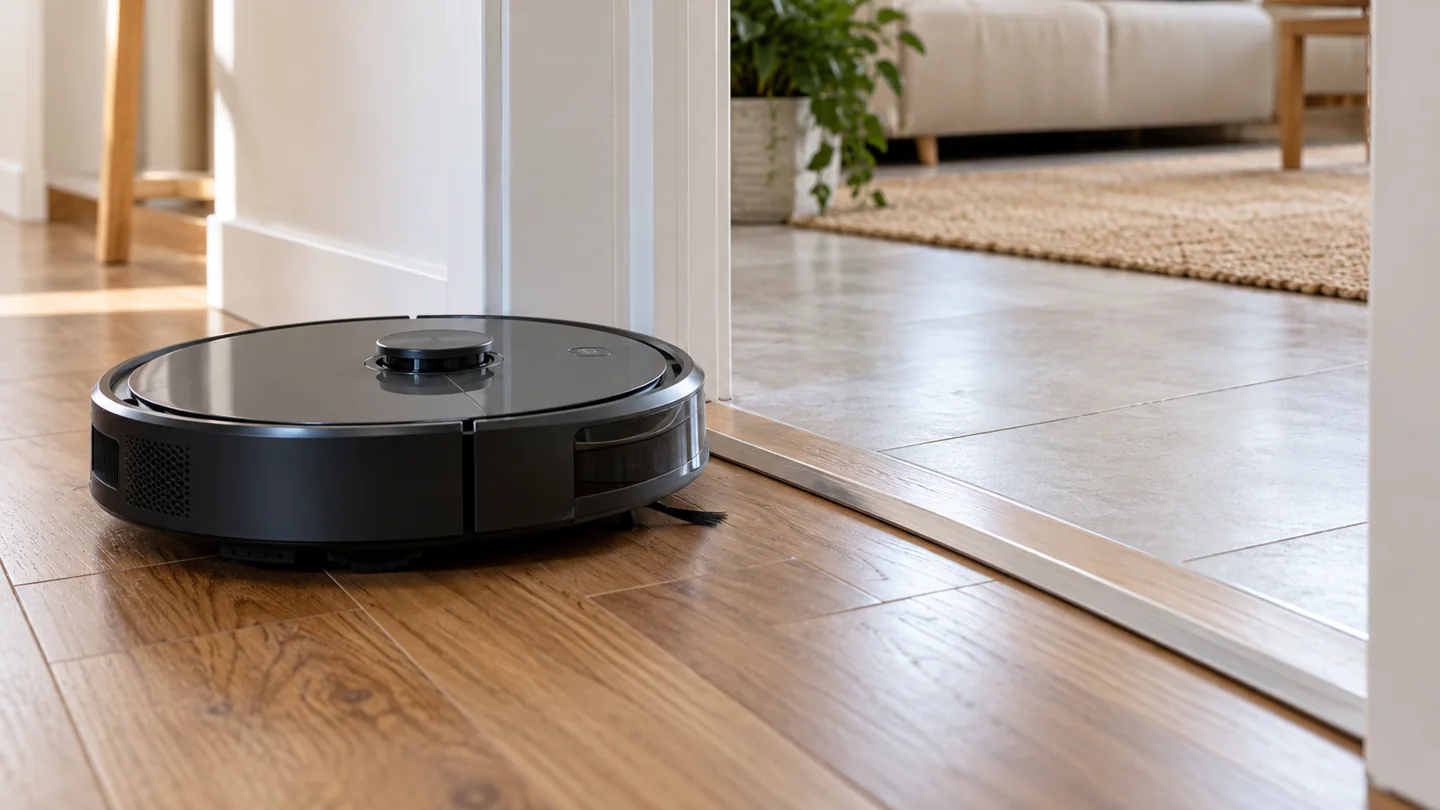
Robot vacuums can cross some bumps and thresholds, but the limit depends on the exact model and the shape of the obstacle. Height alone is not enough: a sharp vertical lip, rounded transition, loose rug, slippery ramp, or double-level threshold can produce different results. Check the manufacturer’s stated capability and test a permitted route under supervision.

Do not assume every robot can climb half an inch, two centimeters, or two inches. Do not assume an app lets you set a universal maximum climbing height. Navigation settings, carpet suction boost, and physical obstacle-crossing capability are separate features.
What kind of bump are you dealing with?
| Obstacle | What can make it difficult | Useful response |
|---|---|---|
| Doorway threshold | Vertical lip, narrow top, two height changes, slippery finish | Measure the full profile and compare with the exact model guidance |
| Rug edge | Loose backing, fringe, curling, soft pile compressing under wheels | Check rug compatibility and stabilize only by an approved method |
| Chair or table base | A sloping edge that admits the front then lifts the body | Exclude the base if the robot repeatedly beaches itself |
| Floor joint or damaged strip | Lifted edge, loose material, sharp contact point | Address the flooring fault rather than forcing the robot across |
| Step or unsafe drop | Fall risk beyond ordinary floor transitions | Protect the boundary as the manual requires; do not use a ramp to bypass it |
Use model specifications carefully
Manufacturer figures can be helpful when their conditions match the obstacle. Roborock’s threshold guidance for several older models lists different limits, including a lower figure for the S4. That historical family guidance should not be applied to every newer robot.
A separate Roborock comparison of Qrevo Curv variants describes different capabilities for standard and double-layer thresholds. The example shows why both the product version and obstacle profile matter.
Read the accompanying diagram and conditions, not just the largest number. A robot that crosses a specified test threshold is not guaranteed to cross every real-world obstacle of the same measured height.
Measure the transition from both directions
Use a ruler to measure the rise from the lower surface to the obstacle’s top, the length of any slope, and the drop or second rise on the far side. Include carpet pile or a raised mat where it changes the robot’s approach.
Look at the actual route. A threshold may be easy from one side and difficult from the other. The robot also needs to return to its dock, so a one-way successful crossing is not enough for a reliable unattended job.
Take a side-on photograph with the ruler visible if you need manufacturer advice. “A small bump” is less useful than the profile, dimensions, floor material, and exact robot model.
Traction and approach can change the result
Wheels need grip to climb. Dust, a slick surface, a loose rug, or an unstable accessory can cause spinning. A diagonal approach may interact differently with an obstacle than a straight one, but do not force repeated attempts outside the manufacturer’s instructions.
The robot’s underside can also contact the obstacle before its wheels gain support. A narrow raised strip can leave the machine balanced with poor traction. More suction does not correct that geometry.
Inspect the wheels and underside with power isolated. Remove ordinary debris and check for damage. Do not add tape, glue, improvised tread, or weights to alter climbing behavior.
Carpet boost is not a climbing mechanism
Some robots increase suction when they detect carpet. That feature affects the cleaning system; it does not automatically enlarge the wheels, raise the chassis, or make a steep lip passable. Other products have separate lifting or obstacle-crossing hardware.
Similarly, a floating cleaning head is not necessarily a whole-body height adjustment. Read which component moves and what the feature is intended to do. Avoid assuming every robot changes its height whenever it detects carpet.
For the separate floor-transition question, see moving from hardwood to carpet. Reaching a rug and cleaning it effectively are different tests.
What to do when the robot repeatedly gets stuck
- Stop the repeated attempts. Prevent further wheel spinning or scraping while you inspect the area.
- Check the model’s limit. Compare the actual profile, not only its approximate height.
- Inspect the obstacle. Look for a loose strip, curled edge, fringe, grit, or a slippery surface.
- Inspect the robot. Check accessible wheels, roller, caster, and underside with power isolated.
- Choose a suitable boundary or route. Use supported no-go zones or compatible physical barriers where needed.
- Consider an appropriate transition solution. Ask the floor installer or manufacturer before altering fixed flooring.
Do not cover cliff sensors to make the robot cross. A sensor reacting to a surface can look like a climbing problem, but bypassing it can remove protection elsewhere. Roborock’s dark-carpet explanation illustrates that distinction.
Would a threshold ramp help?
A stable compatible ramp can turn a permitted abrupt transition into a more gradual approach. It still needs the right height, length, width, traction, edge shape, and attachment method. A loose accessory that slides under the wheels may make the route less reliable.
Consider people using the doorway too. A ramp should not create a trip hazard, obstruct a door, interfere with required accessibility, or damage the floor finish. Adhesive and rubber backing need compatibility checks.
Our threshold-ramp guide explains the selection process. Do not apply one unsupported “maximum slope” to every robot, and do not alter a structural step simply to extend a cleaning route.
Prepare a realistic supervised test
Test only after confirming that the route is appropriate. Clear nearby objects and keep pets away. Watch the approach, crossing, turn, and return rather than lifting the robot over halfway through and calling it successful.
Stop if there is scraping, repeated spinning, a loose transition, or a warning. Check the floor and robot afterward. A route that works once but repeatedly fails during normal jobs may need exclusion or a different cleaning plan.
For recurring interruptions, see robot stopping troubleshooting. Keep the machine maintained using the robot care checklist.
Frequently asked questions
Can every robot cross a two-centimeter threshold?
No. Capabilities differ, and the threshold’s shape and conditions matter. Check the exact product guidance rather than applying a common figure universally.
Can I increase the climb height in the app?
Only use settings actually provided for your model. A suction setting or map boundary does not change physical climbing hardware. Do not assume a generic height control exists.
Should I keep letting it try?
Repeated failure is a reason to stop and inspect. Continued spinning or scraping can waste the session and risk damage. Resolve or exclude the obstacle.
Match the robot to the transition
Measure the obstacle, check the exact model, and confirm a safe return route. A reliable crossing depends on geometry, traction, and compatibility—not one universal bump height or suction figure.
Further reading
How Often To Run Robot Vacuum?

Katy James contributes vacuum-cleaner explainers and practical cleaning guidance at GlobVacs. Her published topics include robot-vacuum operation and vacuum airflow. Read her author profile and selected articles.